About the Project
University of Maryland - Spring 2026
Course: ENPM 701 Grand Challenge (final project)
A Raspberry Pi 4B robot that starts in the launch zone of a 7x7 ft arena, finds red, green, and blue blocks, picks them up, and delivers them to the collection zone with no human input.
Project Highlights
- Mission state machine (localize, search, approach, grab, carry home, drop, step out) that collects blocks in color order under a 10-minute hard limit
- Grid-based search planner that tracks cell visit counts and cached block sightings, with 360-degree camera scans
- HSV color detection with calibrated camera intrinsics and offline tuning tools
- Pose tracking from hardware-timed encoder odometry (pigpio), IMU heading, and ultrasonic wall localization
- Custom 3D-printed chassis mounts (FreeCAD) and KiCad electrical schematic and board layout
- 209 unit tests covering the state machine, motion, search, localization, mapping, and vision
Results
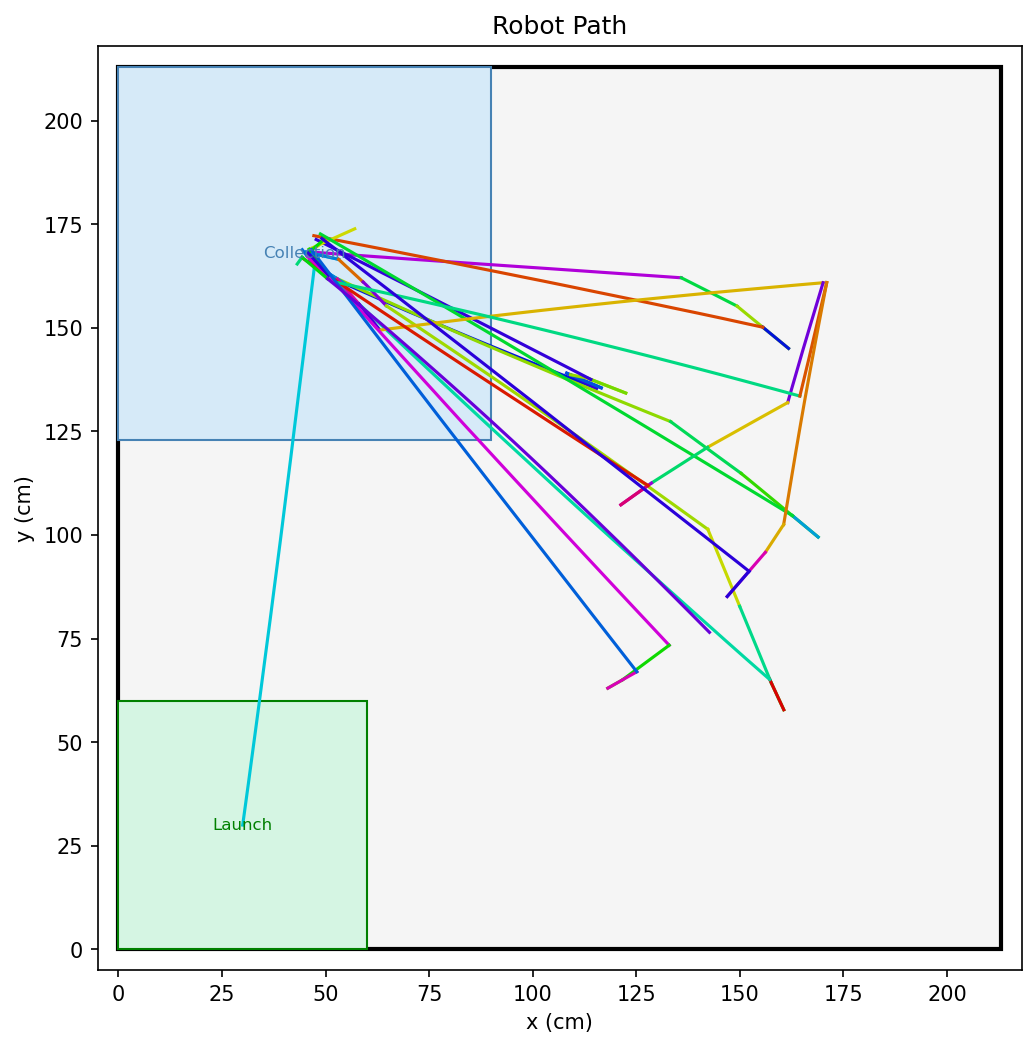
Recorded path from a full run: the robot leaves the launch zone (bottom left) and makes repeated trips between blocks and the collection zone (top left).
Technologies Used
- Python 3
- OpenCV
- Raspberry Pi 4B, pigpio
- Arduino (IMU serial bridge)
- FreeCAD, KiCad
- pytest